
check

check

check

check
check
check
check
check

check

check
Choose a long-range inductive proximity sensor by defining the real non-contact metal detection task before comparing product families. Record the target or measured object, operating range, motion, mounting geometry, environment, controller interface, and acceptance test. Use the worst permitted condition rather than the easiest sample, and verify every numerical limit against the current data sheet for the exact model. A category description can identify a technology direction, but it cannot prove model-level distance, response, accuracy, ingress protection, temperature limits, wiring, or certification.

The primary task is long distance inductive sensor selection by target metal and size. This article treats that phrase as one engineering decision, not as a claim that every product in a category fits the application. The boundary includes the actual target or measured object, minimum and maximum operating condition, installation geometry, control interface, environment, consequence of failure, and evidence required for approval.
A long-range inductive proximity sensor should be evaluated with the actual metal grade and target dimensions. Surrounding metal, mounting construction, target approach, and tolerance stack can change the reliable switching zone. Treat additional distance as a mounting and interference trade-off. Verify assured operation, target size and material, nearby metal or background, mutual interference, response, and bracket stability.
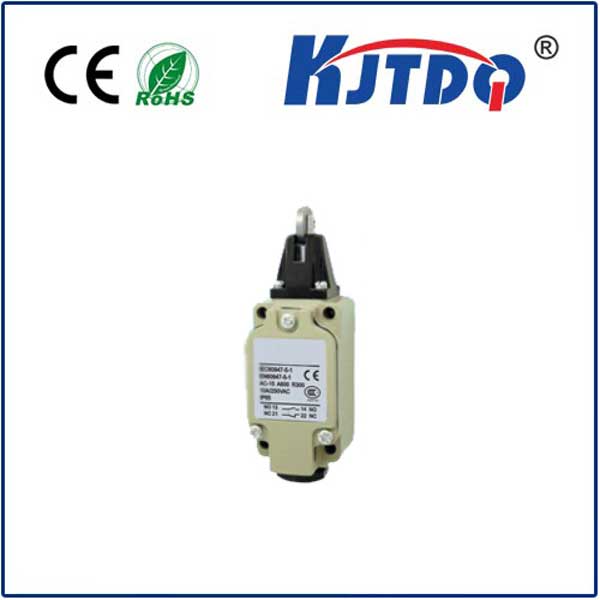
The phrase long range inductive proximity sensor for metal detection defines the product entity by function, not by appearance. For long-range inductive proximity sensor, confirm the sensing principle, intended target, output expected by the controller, and the boundary between detection and measurement. A product photo or category label cannot establish those capabilities. The entity definition is complete only when an exact model and current document set support the application.
Treat extended range metal sensor with increased mounting clearance as a combined mechanical and signal-chain task. Verify bracket datum, orientation, clearance, cable route, connector access, supply, logic, controller timing, diagnostics, and restart behavior. Treat additional distance as a mounting and interference trade-off. Verify assured operation, target size and material, nearby metal or background, mutual interference, response, and bracket stability. Record the final installation so a replacement or maintenance action can reproduce the approved geometry and settings.
For long distance inductive sensor selection by target metal and size, build a selection window with minimum, normal, and maximum conditions. Compare candidates on the same dimensions: target behavior, usable range, mechanical tolerance, response, interface, environment, and required documents. Reject any candidate whose exact-model evidence does not cover a mandatory condition. The remaining candidate still requires a sample test using written pass/fail criteria.
Treat extended range proximity sensor mounting near surrounding metal as a combined mechanical and signal-chain task. Verify bracket datum, orientation, clearance, cable route, connector access, supply, logic, controller timing, diagnostics, and restart behavior. Treat additional distance as a mounting and interference trade-off. Verify assured operation, target size and material, nearby metal or background, mutual interference, response, and bracket stability. Record the final installation so a replacement or maintenance action can reproduce the approved geometry and settings.
Use long range inductive sensor false triggering troubleshooting as a symptom-led diagnostic task. Reproduce the symptom safely, confirm the real process state, inspect the target and sensing interface, measure alignment or gap through a complete cycle, verify power and controller status, and change one factor at a time. Preserve the result before and after each correction so the root cause is not hidden by simultaneous adjustments.
Specify performance as a bounded operating window, not a single headline value. Record minimum, normal, and maximum conditions, add mechanical and process tolerances, and define the acceptance margin. For long-range inductive proximity sensor, distinguish nominal range from assured operation, resolution from accuracy, response time from total event-capture time, and reference-target data from the real target. Only exact-model values with stated test conditions belong in the design calculation.
Record minimum, normal, and maximum requirements.
Separate nominal, assured, repeatability, accuracy, and response terms.
Add mechanical and process tolerance.
Bind every design value to an exact-model source.
Include target metal, dimensions, approach, gap, and surrounding metal.

Mount the long-range inductive proximity sensor so the intended target crosses a stable sensing or measurement region without collision, cable strain, bracket movement, uncontrolled background influence, or inaccessible adjustment. Use the exact drawing for orientation, clearance, thread engagement, sealing, optical axis, actuator travel, or metal-free zones. Commission at the worst mechanical position, lock the setting, record the final geometry, and recheck after vibration, thermal cycling, cleaning, or maintenance.
Create a mounting drawing with datum and target path.
Check clearance, collision, strain, alignment, and service access.
Commission at worst mechanical position.
Lock and record the approved geometry.
Include target metal, dimensions, approach, gap, and surrounding metal.
Troubleshoot from the observable symptom and the lowest-risk checks first. Confirm the real process state, inspect the sensing face or actuator, measure gap and alignment through a complete cycle, verify supply and controller status, and compare the installed model code with its documents. Common causes for long-range inductive proximity sensor include contamination, target variation, bracket movement, cable damage, incorrect logic, filtering, and operation outside the verified boundary. Change one factor at a time and retain the before-and-after result.
Capture the symptom before changing settings.
Check target, mechanics, contamination, power, and controller state.
Change one factor at a time.
Retest the full machine cycle and retain evidence.
Include target metal, dimensions, approach, gap, and surrounding metal.
| Decision | Rule | Evidence before approval |
|---|---|---|
| Metal target | Record material, size, approach direction, and worst-case gap | Target drawing and sample test |
| Operating window | Record minimum, normal, and maximum conditions with tolerance | Exact-model data sheet and calculation |
| Mounting | Check space, alignment, clearance, mechanical travel, and service access | Approved drawing and installation review |
| Electrical or data interface | Match supply, output, logic, timing, connector, and controller | Wiring or protocol document and I/O test |
| Environment | List temperature, ingress, chemicals, vibration, contamination, and ambient effects | Model limits and representative environmental test |
| Acceptance | Define pass/fail behavior before ordering | Commissioning record and retained evidence |
Do not populate this matrix with assumed values. Use the exact-model data sheet, drawing, wiring or protocol document, certificate where applicable, and a controlled application test.
Test the actual metal grade and smallest target at the maximum permitted gap, then repeat with bracket tolerance, runout, nearby metal, contamination, minimum pulse duration, and supply variation. Record both approach and release behavior where the control logic depends on hysteresis.
Use a controlled sequence:
Record model identity and document revision.
Photograph or measure the approved installation geometry.
Establish a normal baseline at the controller.
Exercise each minimum and maximum condition.
Introduce one credible disturbance at a time.
Record pass, fail, invalid, and recovery behavior.
Repeat after final installation if the fixture changed.
| Symptom | First checks | Controlled action |
|---|---|---|
| No switch | Gap, target metal/size, surrounding metal, supply | Verify the evidence, correct one cause, and repeat the acceptance test |
| Intermittent | Runout, bracket movement, chips, pulse duration | Verify the evidence, correct one cause, and repeat the acceptance test |
| Always active | Nearby metal, mounting construction, damaged face | Verify the evidence, correct one cause, and repeat the acceptance test |
Stop diagnosis before bypassing guards, emergency circuits, hazardous-area controls, or site isolation procedures. High-consequence behavior requires the responsible engineer.
Send KJT Sensors the application function, target or process description, operating window, mounting drawing, speed or timing, environment, supply and controller interface, connector or protocol, destination market, required documents, prototype quantity, and written sample-test criteria. Request the current exact-model data sheet and drawing with the response.
How to Choose Inductive Proximity Sensors for Industrial Metal Detection — Review the broader product-family selection framework before narrowing the model.
How to Choose a Miniature Inductive Proximity Sensor for Compact Machines — Compare this adjacent selection task to keep the application boundary and evidence requirements distinct.
How to Choose an Analog Inductive Sensor for Continuous Position Measurement — Compare this adjacent selection task to keep the application boundary and evidence requirements distinct.
Select long-range inductive proximity sensor by matching the technology to the real task and then proving the exact model across the full operating boundary. The decision is complete only when mechanical fit, signal behavior, environment, controller response, documentation, and worst-case sample testing agree. Category descriptions support discovery; they do not replace model-level engineering approval.
KJT Sensors long-range inductive proximity sensor category — family-level context supplied in the approved brief; verify the live page and exact-model documents before publication.